|
Thales Costa Silva I'm a postdoctoral research associate in the Automatic Coordination of Teams (ACT) Lab in the Department of Computer Science at Brown University, where I work with Nora Ayanian. Before Brown, I was a postdoctoral researcher at the GRASP Lab at the University of Pennsylvania, working with M. Ani Hsieh. I received my M.Sc. and Ph.D. in Electrical Engineering from the Universidade Federal de Minas Gerais in Brazil, advised by Luciano Pimenta and Fernando Souza. |
|
News
Older news |

ResearchI work on multi-robot systems that learn and act in unknown, dynamic environments such as ocean currents and wind fields. My research covers learning models of these environments from data the robots collect themselves, deciding where the team should explore next under communication constraints, and robust and learning-based control for aerial robots. My background is in distributed control of multi-agent systems, with stability guarantees under constraints. Some papers are highlighted. |
|
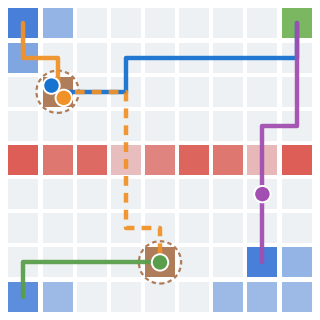
Probabilistic Multi-Robot Planning with Temporal Tasks and Communication Constraints
Thales C. Silva, Xi Yu, M. Ani Hsieh Autonomous Robots, 50(2), 2026 paper |
|
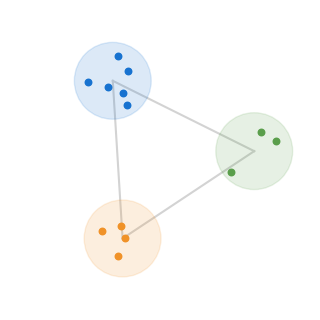
Adaptive Macroscopic Ensemble Allocation for Robot Teams Monitoring Spatiotemporal Processes
Victoria Edwards, Thales C. Silva, M. Ani Hsieh Advanced Intelligent Systems, 2026 paper |
|
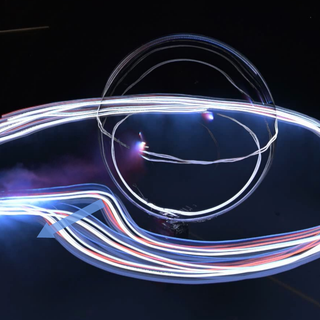
Online Learning-Enhanced High Order Adaptive Safety Control
Lishuo Pan, Mattia Catellani, Thales C. Silva, Lorenzo Sabattini, Nora Ayanian IEEE Robotics and Automation Letters, 11(7):7964–7971, 2026 paper |
|
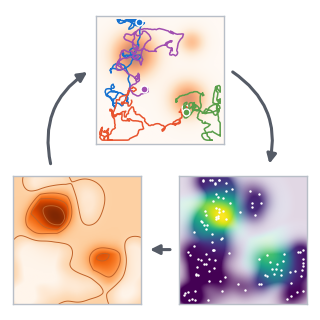
Mind the Gaps: Multi-Robot Feedback-Driven Ergodic Coverage in Unknown Environments
Thales C. Silva, Nora Ayanian American Control Conference (ACC), 2026 |
|
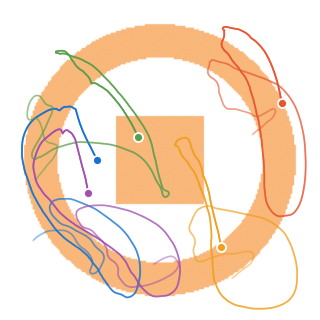
Anisotropic Diffusion-Driven Ergodic Coverage in Multi-Robot Systems
Thales C. Silva, Anoop Kiran, Nora Ayanian IEEE International Symposium on Multi-Robot & Multi-Agent Systems (MRS), 2025 |
|
KoopMotion: Learning Almost Divergence-Free Koopman Flow Fields for Motion Planning
Alice K. Li, Thales C. Silva, Victoria Edwards, M. Ani Hsieh Conference on Robot Learning (CoRL), 2025 |
|
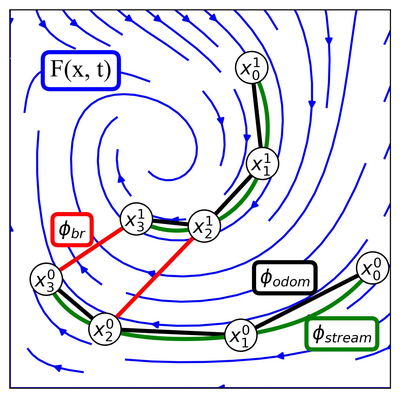
Flow-Based Localization and Mapping for Multi-Robot Systems
Arjun Kumar, Thales C. Silva, Victoria Edwards, M. Ani Hsieh IEEE Robotics and Automation Letters, 10(4):3278–3285, 2025 paper |
|
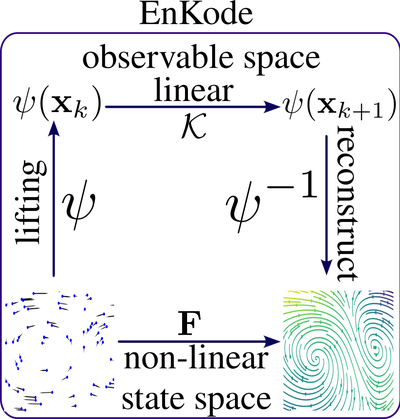
EnKode: Active Learning of Unknown Flows With Koopman Operators
Alice K. Li, Thales C. Silva, M. Ani Hsieh IEEE Robotics and Automation Letters, 9(12):11282–11289, 2024 paper |
|
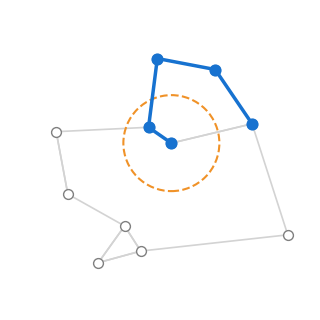
Communication-Constrained Multi-Robot Exploration with Intermittent Rendezvous
Alysson Ribeiro da Silva, Luiz Chaimowicz, Thales C. Silva, M. Ani Hsieh IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024 |
|
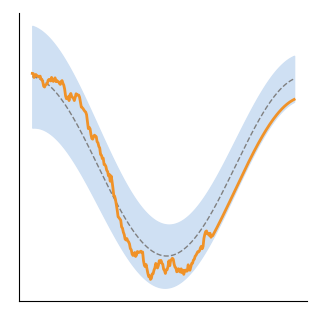
Uncertainty Quantification and Robustification of Model-based Controllers using Conformal Prediction
Kong Yao Chee, Thales C. Silva, M. Ani Hsieh, George J. Pappas Learning for Dynamics & Control Conference (L4DC), PMLR 242:528–540, 2024 |
|
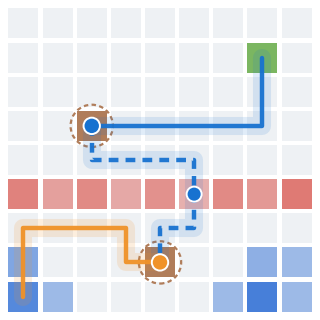
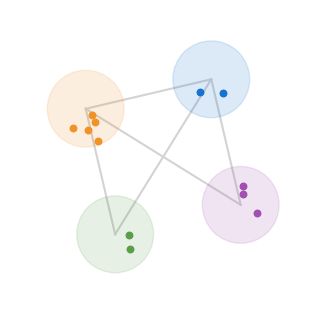
Probabilistic Multi-Robot Planning with Temporal Tasks and Communication Constraints
Thales C. Silva, Xi Yu, M. Ani Hsieh International Symposium on Distributed Autonomous Robotic Systems (DARS), 2024 |
|
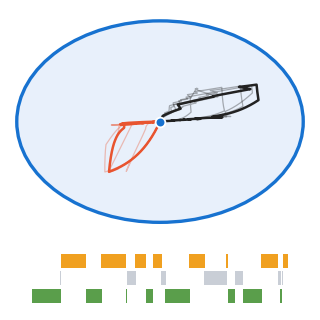
A Macroscopic Ensemble Modeling Approach to Collaborative Task Assignment in Dynamic Environments
Victoria Edwards, Thales C. Silva, M. Ani Hsieh International Symposium on Distributed Autonomous Robotic Systems (DARS), 2024 |
|
Local Input-to-State Stability for Consensus in the Presence of Intermittent Communication and Input Saturation
Thales C. Silva, M. Ani Hsieh IEEE Conference on Decision and Control (CDC), 2023 paper |
|
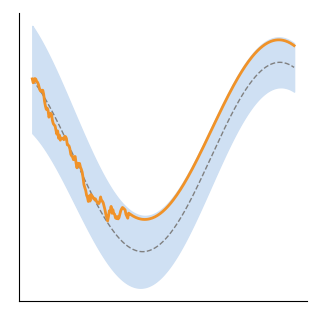
On Collaborative Robot Teams for Environmental Monitoring: A Macroscopic Ensemble Approach
Victoria Edwards, Thales C. Silva, Bharg Mehta, Jasleen Dhanoa, M. Ani Hsieh IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023 paper |
|
Enhancing Sample Efficiency and Uncertainty Compensation in Learning-based Model Predictive Control for Aerial Robots
Kong Yao Chee, Thales C. Silva, M. Ani Hsieh, George J. Pappas IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023 arXiv |
|
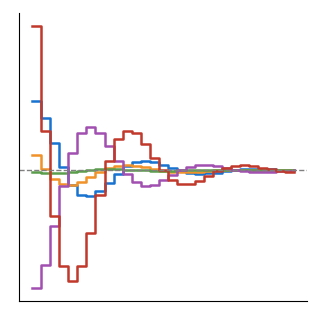
Regional Consensus in Discrete-Time Multi-Agent Systems Subject to Saturating Inputs and Time-Varying Delays
Thales C. Silva, Valter J. S. Leite, Fernando O. Souza, Luciano C. A. Pimenta International Journal of Control, 2023 paper Consensus analysis and distributed protocol design in discrete time, with an estimate of the region of attraction that treats current and delayed states separately. |
|
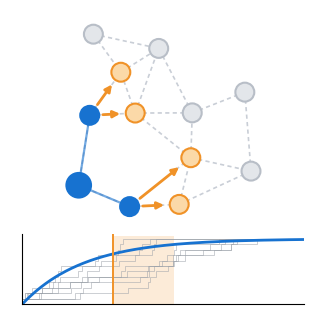
Receding Horizon Control on the Broadcast of Information in Stochastic Networks
Thales C. Silva, Li Shen, Xi Yu, M. Ani Hsieh International Symposium on Distributed Autonomous Robotic Systems (DARS), 2022 |
|
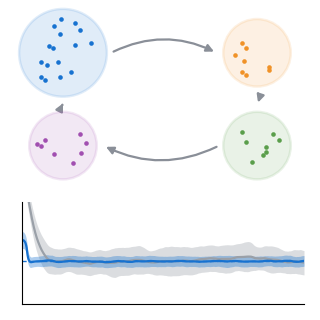
Proportional Control for Stochastic Regulation on Allocation of Multi-Robots
Thales C. Silva, Victoria Edwards, M. Ani Hsieh International Symposium on Distributed Autonomous Robotic Systems (DARS), 2022 |
|
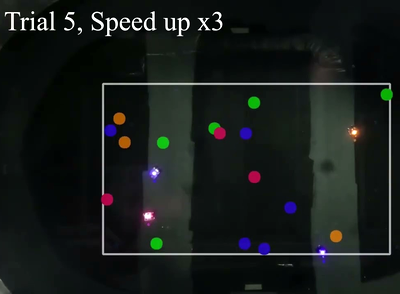
Stochastic Nonlinear Ensemble Modeling and Control for Robot Team Environmental Monitoring
Victoria Edwards, Thales C. Silva, M. Ani Hsieh International Symposium on Distributed Autonomous Robotic Systems (DARS), 2022 |
|
Consensus in Multi-Agent Systems Subject to Input Saturation and Time-Varying Delays
Thales C. Silva, Fernando O. Souza, Luciano C. A. Pimenta International Journal of Systems Science, 52(7):1479–1498, 2021 paper LMI conditions, based on Lyapunov–Krasovskii theory, for consensus of directed networks of linear agents with saturating inputs and non-uniform time-varying delays. |
|
Distributed Formation-Containment Control with Euler-Lagrange Systems Subject to Input Saturation and Communication Delays
Thales C. Silva, Fernando O. Souza, Luciano C. A. Pimenta International Journal of Robust and Nonlinear Control, 30(7):2999–3022, 2020 paper |
Miscellanea |
Education |
Ph.D. in Electrical Engineering, Universidade Federal de Minas Gerais, 2021
M.Sc. in Electrical Engineering, Universidade Federal de Minas Gerais, 2019 B.Sc. in Electrical Engineering, Universidade Federal do Tocantins, 2017 (High Honors) |
Experience |
Postdoctoral Research Associate, ACT Lab, Brown University, 2025–present
Postdoctoral Researcher, GRASP Lab, University of Pennsylvania, 2021–2025 Research Scholar, Control, Automation, and Robotics Lab, UFMG, 2017–2021 Research Scholar, Universidade Federal do Tocantins, 2014–2016 |
Mentoring |
Brown: Lishuo Pan (Ph.D.), Anoop Kiran (Ph.D.)
UPenn: Arjun Kumar (Ph.D.), Alice K. Li (Ph.D.), Victoria Edwards (Ph.D.), Urara Kono (M.S.), Li Shen (M.S.) |
Teaching |
Teaching Assistant, Digital Systems Design and Practice, UFMG
Teaching Assistant, Principles of Electromagnetism, UFT Teaching Assistant, Differential Calculus, UFT Teaching Assistant, Linear Algebra, UFT |
|
Yet another website based on Jon Barron. |